
Visual inspection & sorting
Define the object, defect and cycle time before choosing cameras, lighting and edge compute.
Typical purchasing teams
Machine-vision integrators, robotics startups building bin-picking cells, and factory automation teams validating a first station.
Prepare the supplier brief
Record object size and material, smallest feature, working distance, conveyor speed, available installation space, ambient light and permitted false-accept / false-reject rates.
Depth camera
What should you compare?
Compare usable depth range, field of view at working distance, depth error under your surface conditions, trigger / synchronization, USB bandwidth and SDK support.
What gets missed in a quote?
Ask whether cables, mounts, calibration files, multi-camera synchronization and SDK integration support are included.
D405
Specification source checked 2026-11-07
ZED 2i 2.1 mm
Specification source checked 2026-11-07
ZED 2i 4.6 mm
Specification source checked 2026-11-07
D455
Specification source checked 2026-11-07
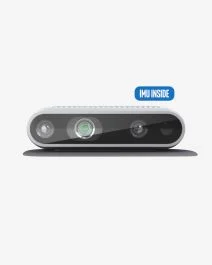
D435i
Specification source checked 2026-11-07
OAK-D Pro AutoFocus
Specification source checked 2026-11-07
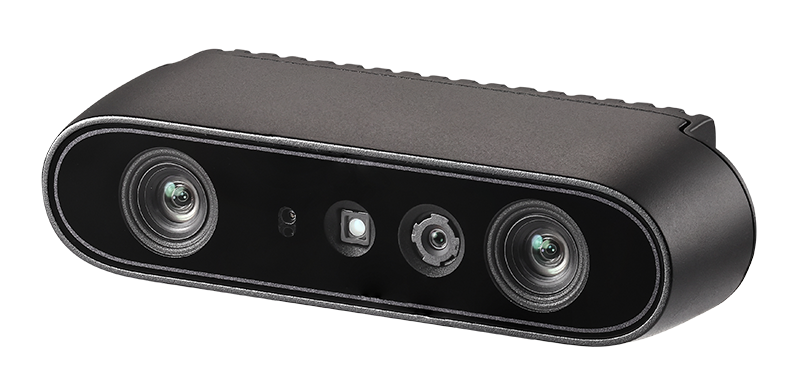
Gemini 335 · G40155-170
Specification source checked 2026-11-06
Gemini 336 · G40155-180
Specification source checked 2026-11-06
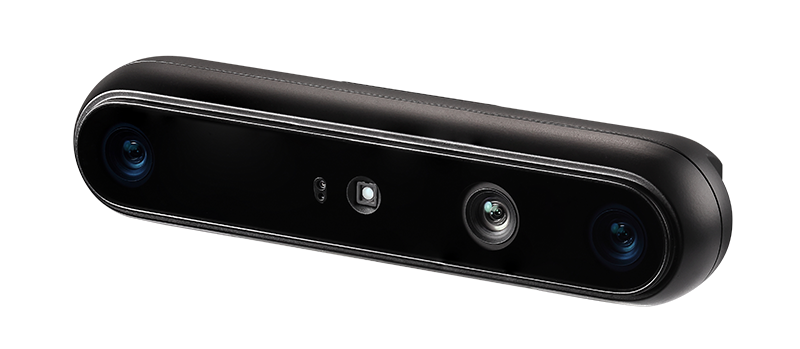
Gemini 335L · G40055-170
Specification source checked 2026-11-06
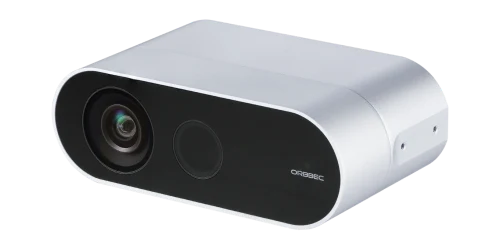
Femto Bolt · F00364-152
Specification source checked 2026-11-07
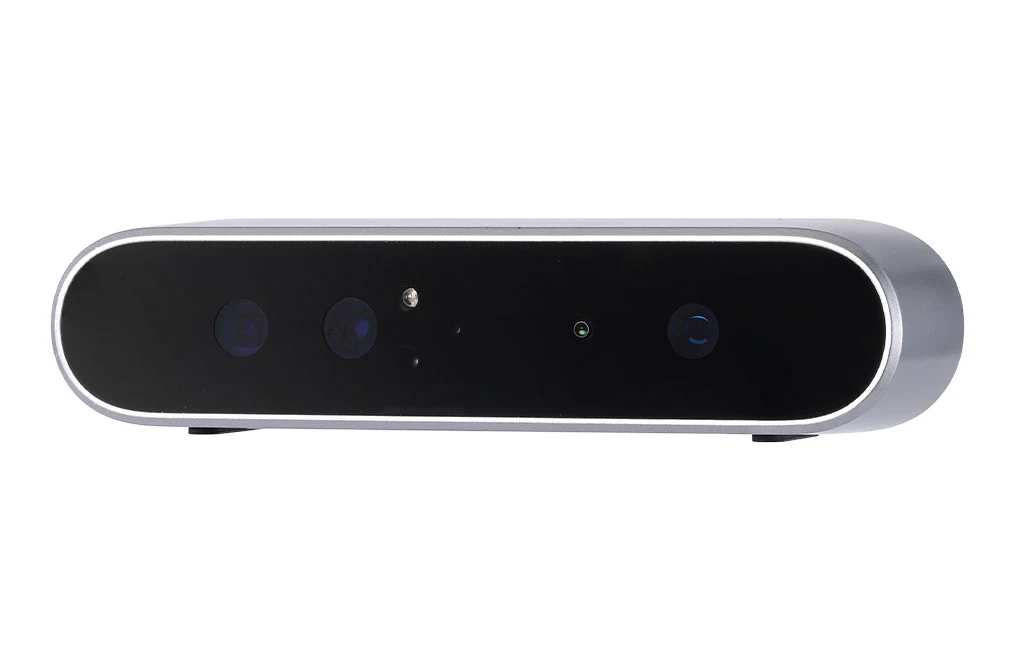
Astra 2
Specification source checked 2026-11-08
Gemini 338Le
Specification source checked 2026-11-08
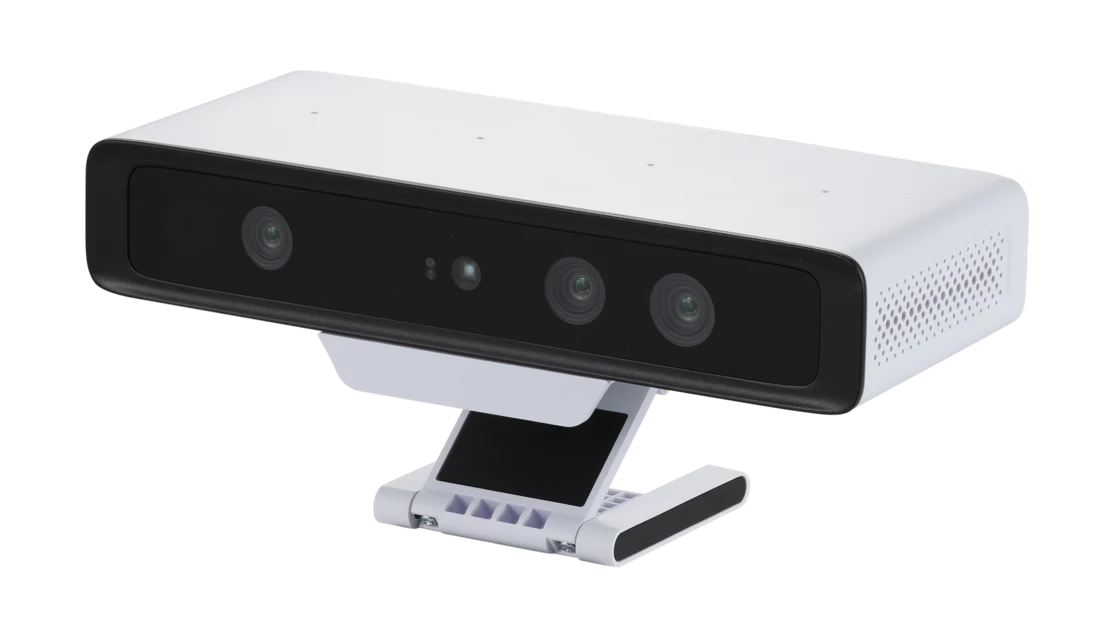
Persee 2 · 4GB / 32GB
Specification source checked 2026-11-08
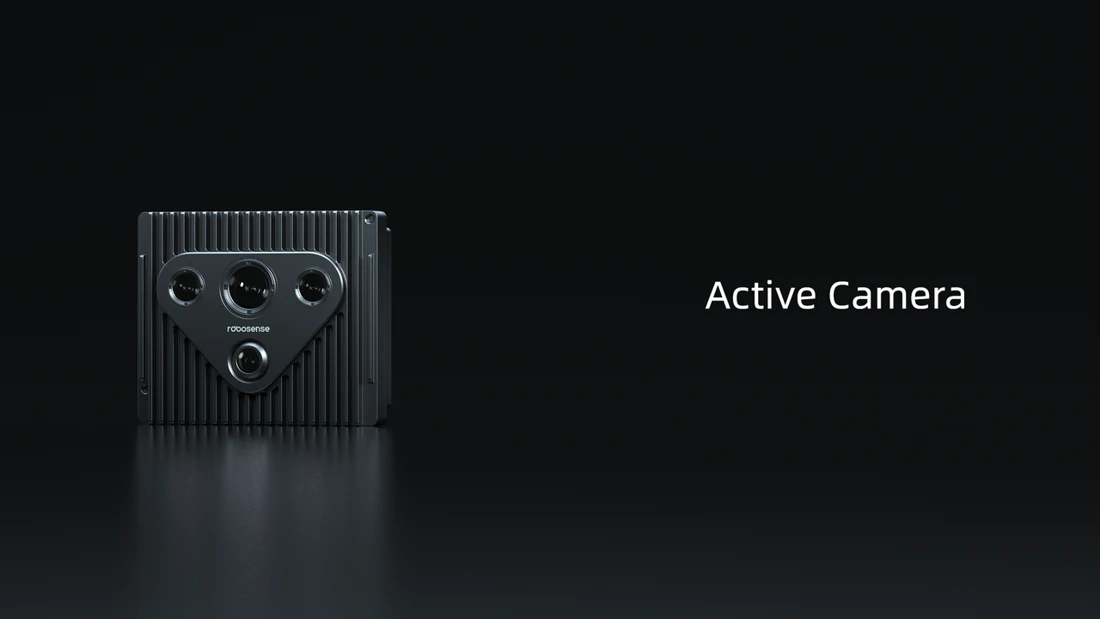
AC1
Specification source checked 2026-11-08
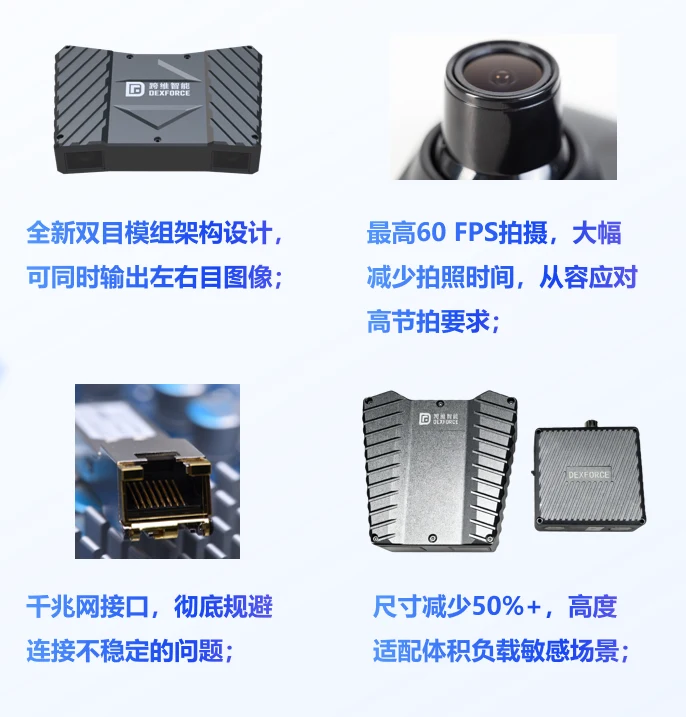
KINGFISHER-S-602
Specification source checked 2026-11-08
Machine-vision lighting
What should you compare?
Test contrast on real samples. Confirm wavelength, illumination geometry, working distance, exposure, strobe duty cycle and controller compatibility. Use the model-specific parameter table rather than a generic series table.
What gets missed in a quote?
Separate the light from its controller, trigger cable, power supply, diffuser, polarizer and mounting hardware.
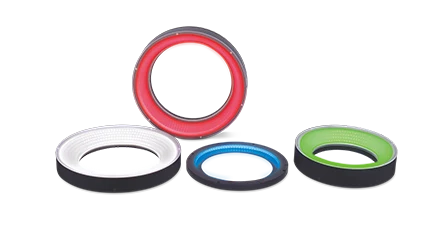
RI5000-R
Specification source checked 2026-11-07
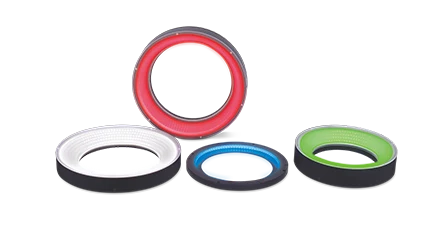
RI7000-R
Specification source checked 2026-11-07
Edge AI compute
What should you compare?
Compare measured end-to-end latency and memory use with your model, camera interfaces, power mode, thermal limits, OS / JetPack version and availability of a reproducible deployment image.
What gets missed in a quote?
Specify the exact SKU, SSD, carrier board, adapter, regional power cord, wireless modules and software support. TOPS is not application throughput.
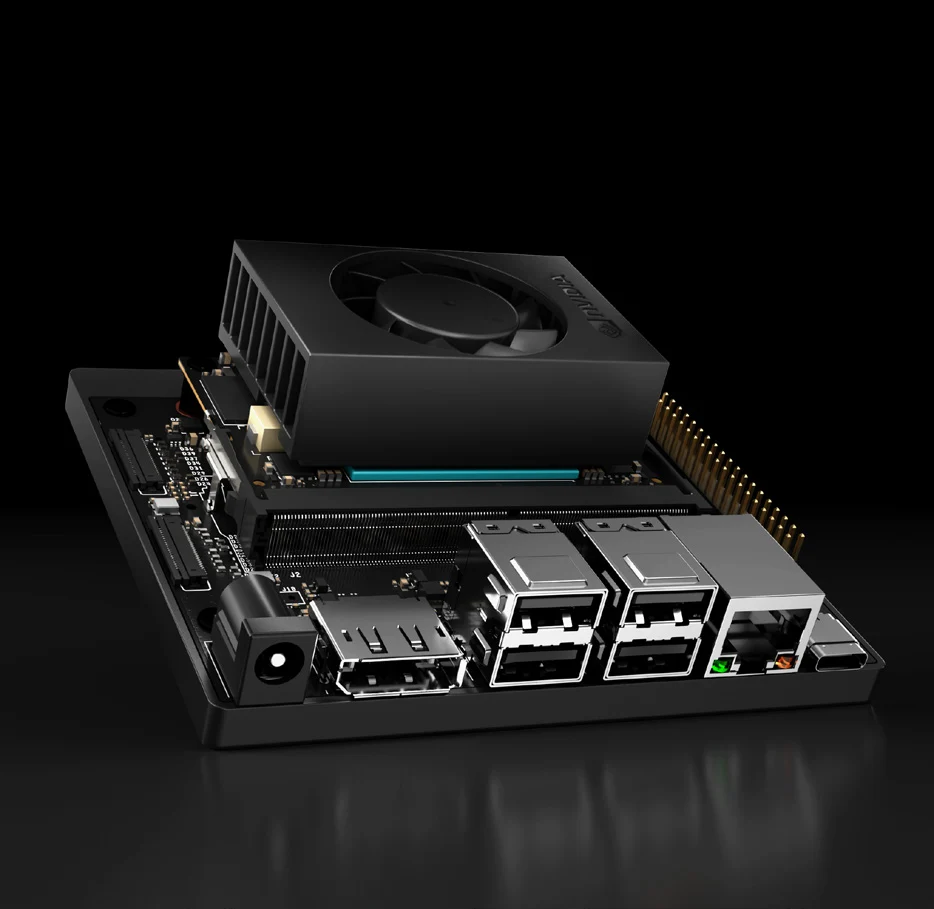
Jetson Orin Nano Super Developer Kit (8GB)
Specification source checked 2026-11-07
reComputer Super J3011 · SKU 114110312
Specification source checked 2026-11-07
reComputer Super J4012 · SKU 114110314
Specification source checked 2026-11-07
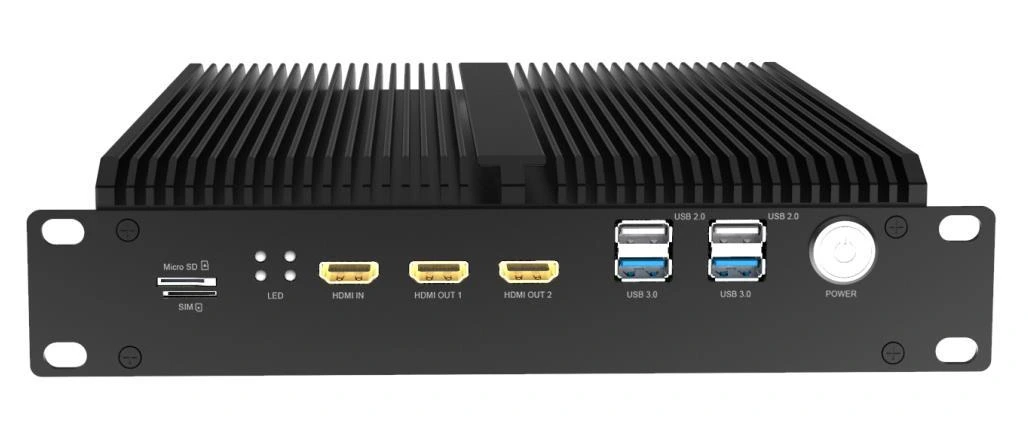
APC3588-AI · 4 GB / 32 GB reference
Specification source checked 2026-11-07
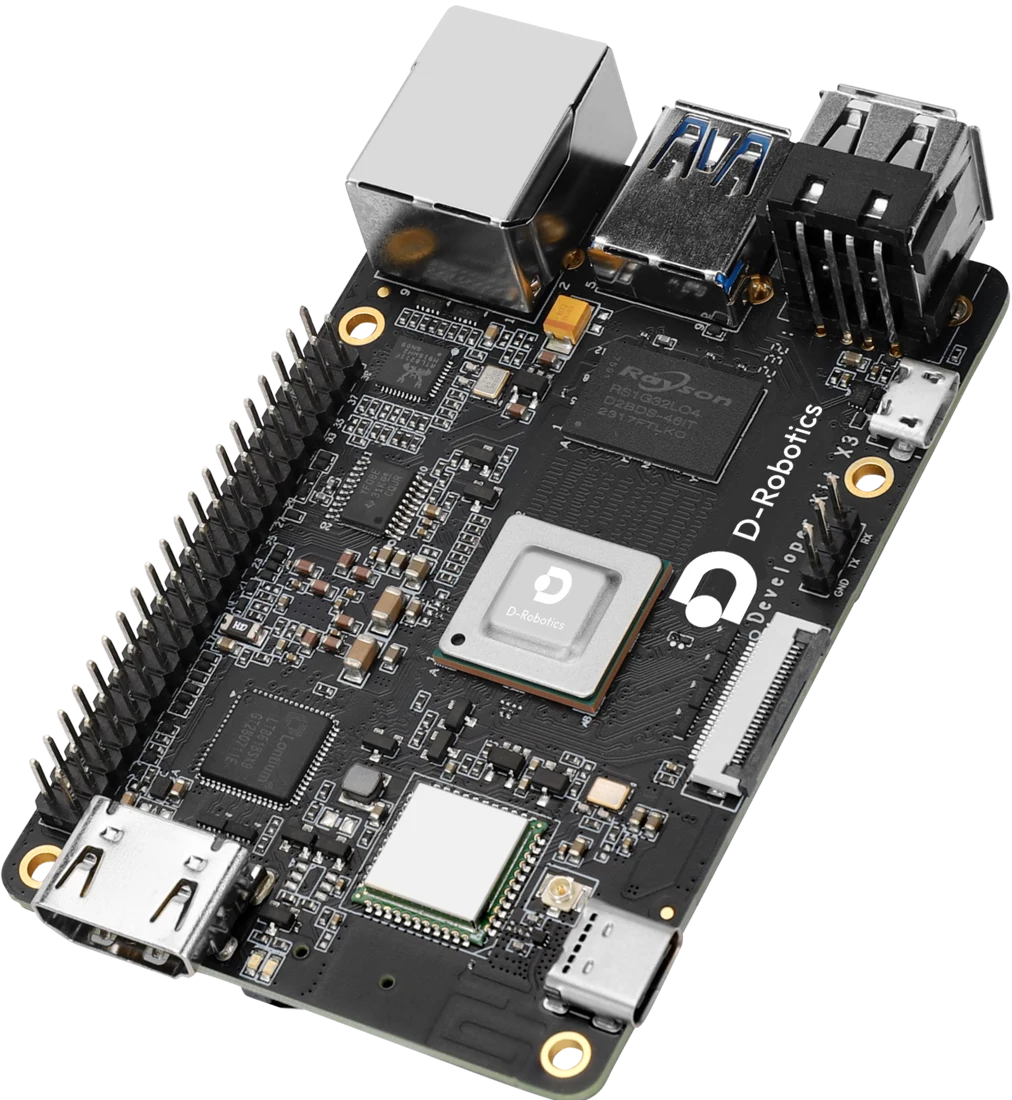
RDK X3 2.0 · 4GB
Specification source checked 2026-11-08
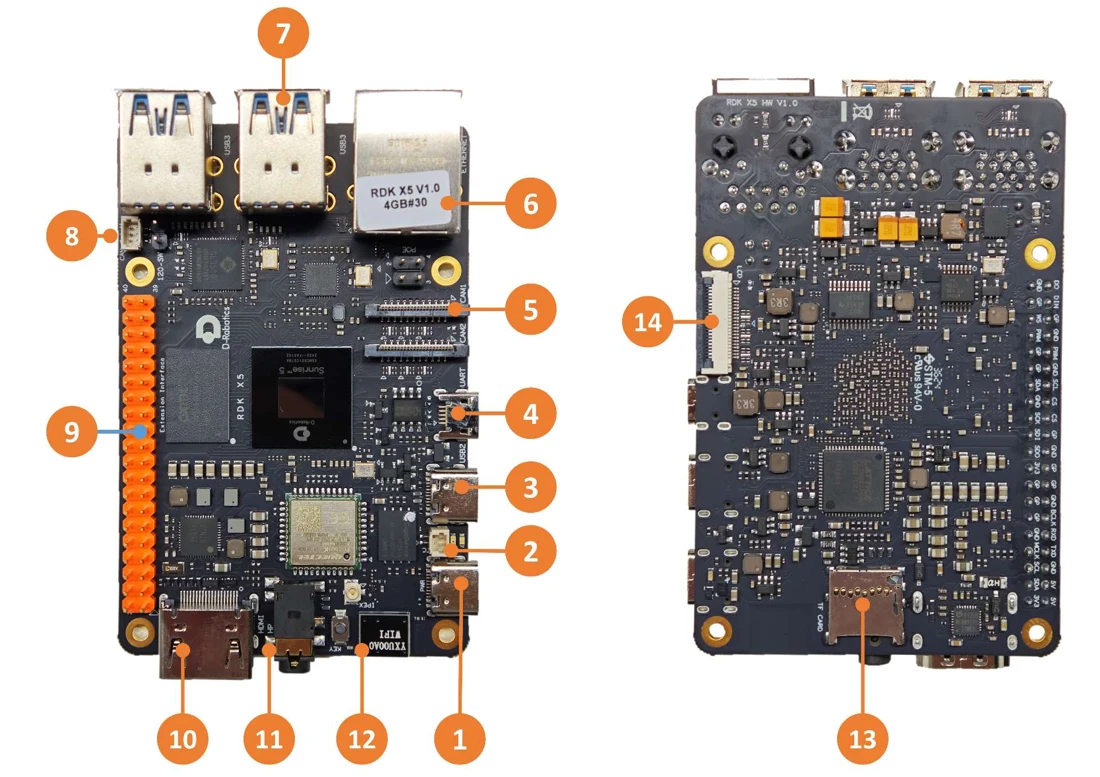
RDK X5 · 8GB
Specification source checked 2026-11-08
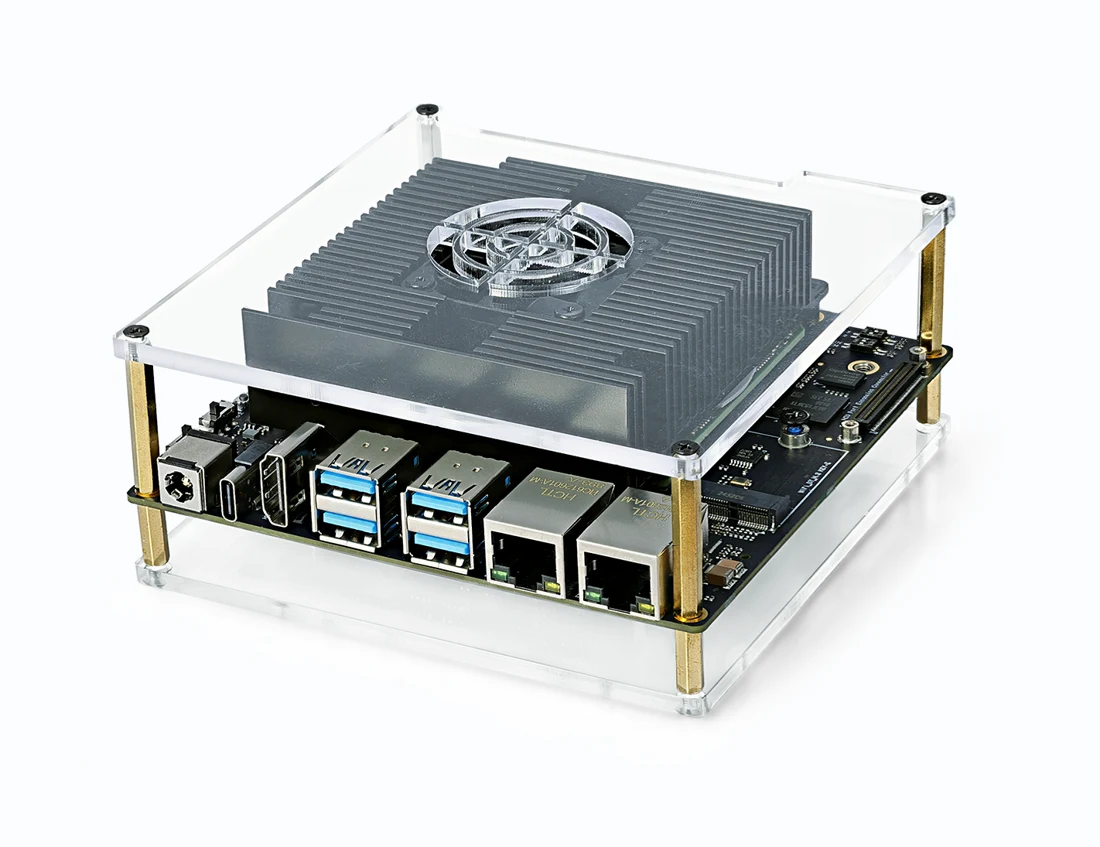
RDK S100 · KS1E55Y · 12GB
Specification source checked 2026-11-08
Electric gripper
What should you compare?
Compare per-jaw force, stroke, grasp geometry, workpiece mass and the selected controller. Validate grip stability on real samples; payload cannot be inferred from jaw force.
What gets missed in a quote?
Itemize jaws, brake, robot adapter, drive / control box, protocol option, cable, calibration and integration support.
PGE-5-26
Specification source checked 2026-11-08
PGE-8-14
Specification source checked 2026-11-08
PGEA-15-26
Specification source checked 2026-11-08
PGEA-50-26
Specification source checked 2026-11-08
PGEA-100-26
Specification source checked 2026-11-08
RY-G1 · 0102-90
Specification source checked 2026-11-08
RY-G1 · 0102-110
Specification source checked 2026-11-08
RY-G1 · 0102-120
Specification source checked 2026-11-08
Industrial vision / code readers
What should you compare?
Distinguish 2D inspection, code reading and 3D geometry. Match the full model suffix, lens, shutter, lighting, working distance, trigger and host integration; these are not interchangeable camera roles.
What gets missed in a quote?
Separate software entitlement, controller / host, adapter, external lighting, cables, lens, commissioning and sample verification.
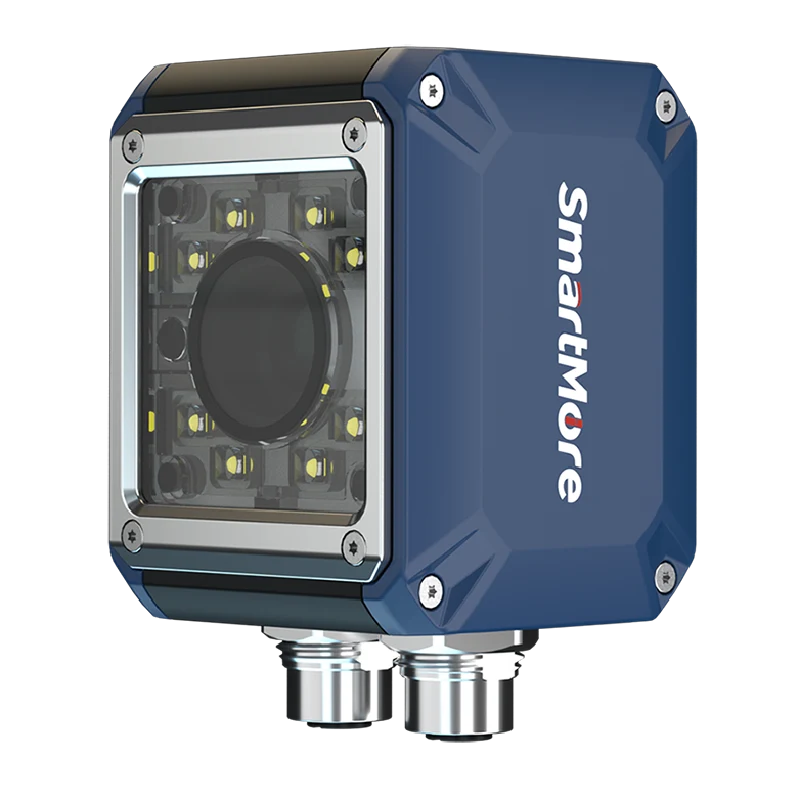
VN4000-101-021
Specification source checked 2026-11-08
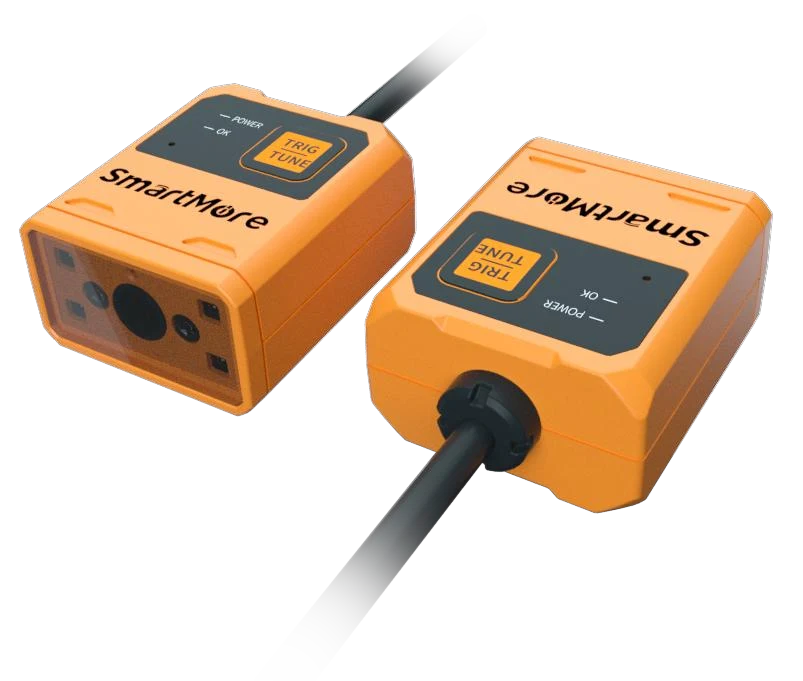
VS600-NR-W
Specification source checked 2026-11-08
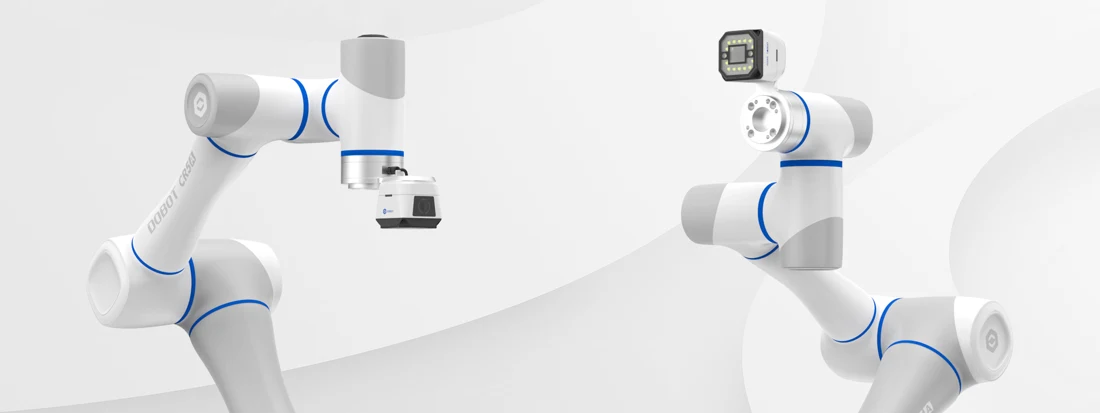
VX500 Smart Camera
Specification source checked 2026-11-08
How should samples be accepted?
- Use a held-out set of good and defective parts, including reflective and dark samples; record lighting, distance and exposure.
- Measure capture-to-decision latency and missed triggers over the intended duty cycle. A depth-camera reference does not prove defect-detection performance.
These are procurement verification questions. Validate performance under your conditions and confirm MOQ, project pricing and lead time in writing.