Pick and Place
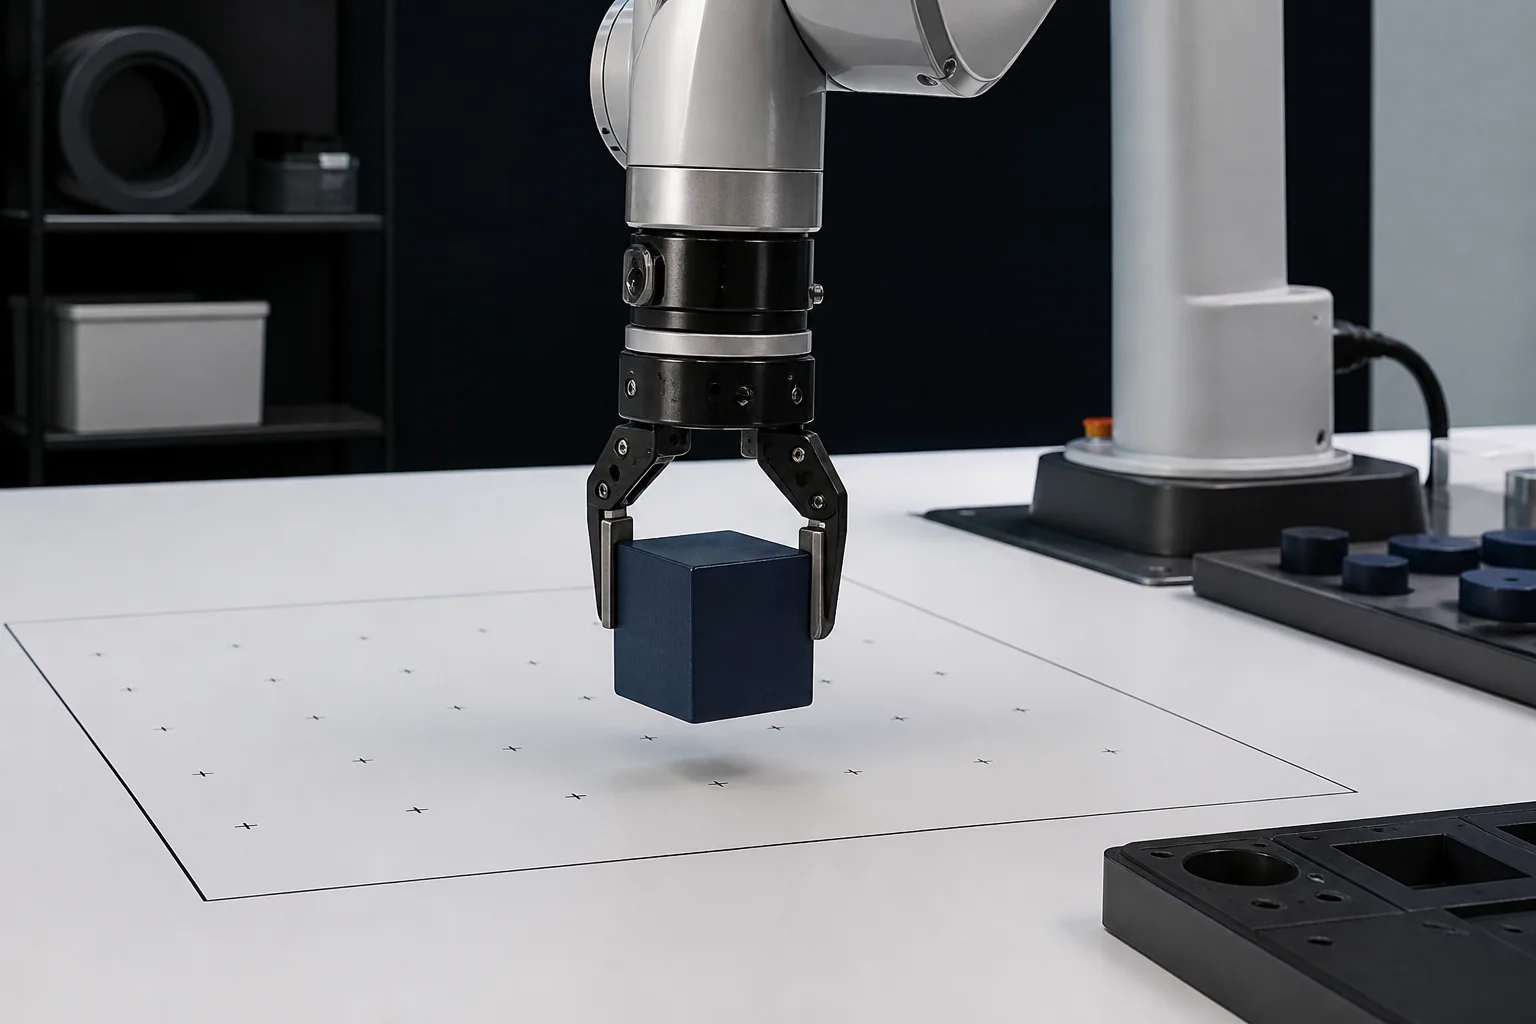
Test grasping, moving and stable placement across different shapes, materials and starting positions.

Final venue and dates will be published after confirmation.
Dexterous manipulation can produce compelling demonstrations, yet object variation, tool variation and repeated operation quickly reveal system boundaries.
It is a useful first test of RobotBay’s public method: the task can be described, conditions made visible, and failure and recovery recorded.
Test grasping, moving and stable placement across different shapes, materials and starting positions.
Test grasping, reorientation and use of a simple tool to complete a defined action.
Test recognition, grasping and classification when the object set is not completely fixed.
These are initial directions. Final task specifications will be published after confirmation with participants and real-world operators.
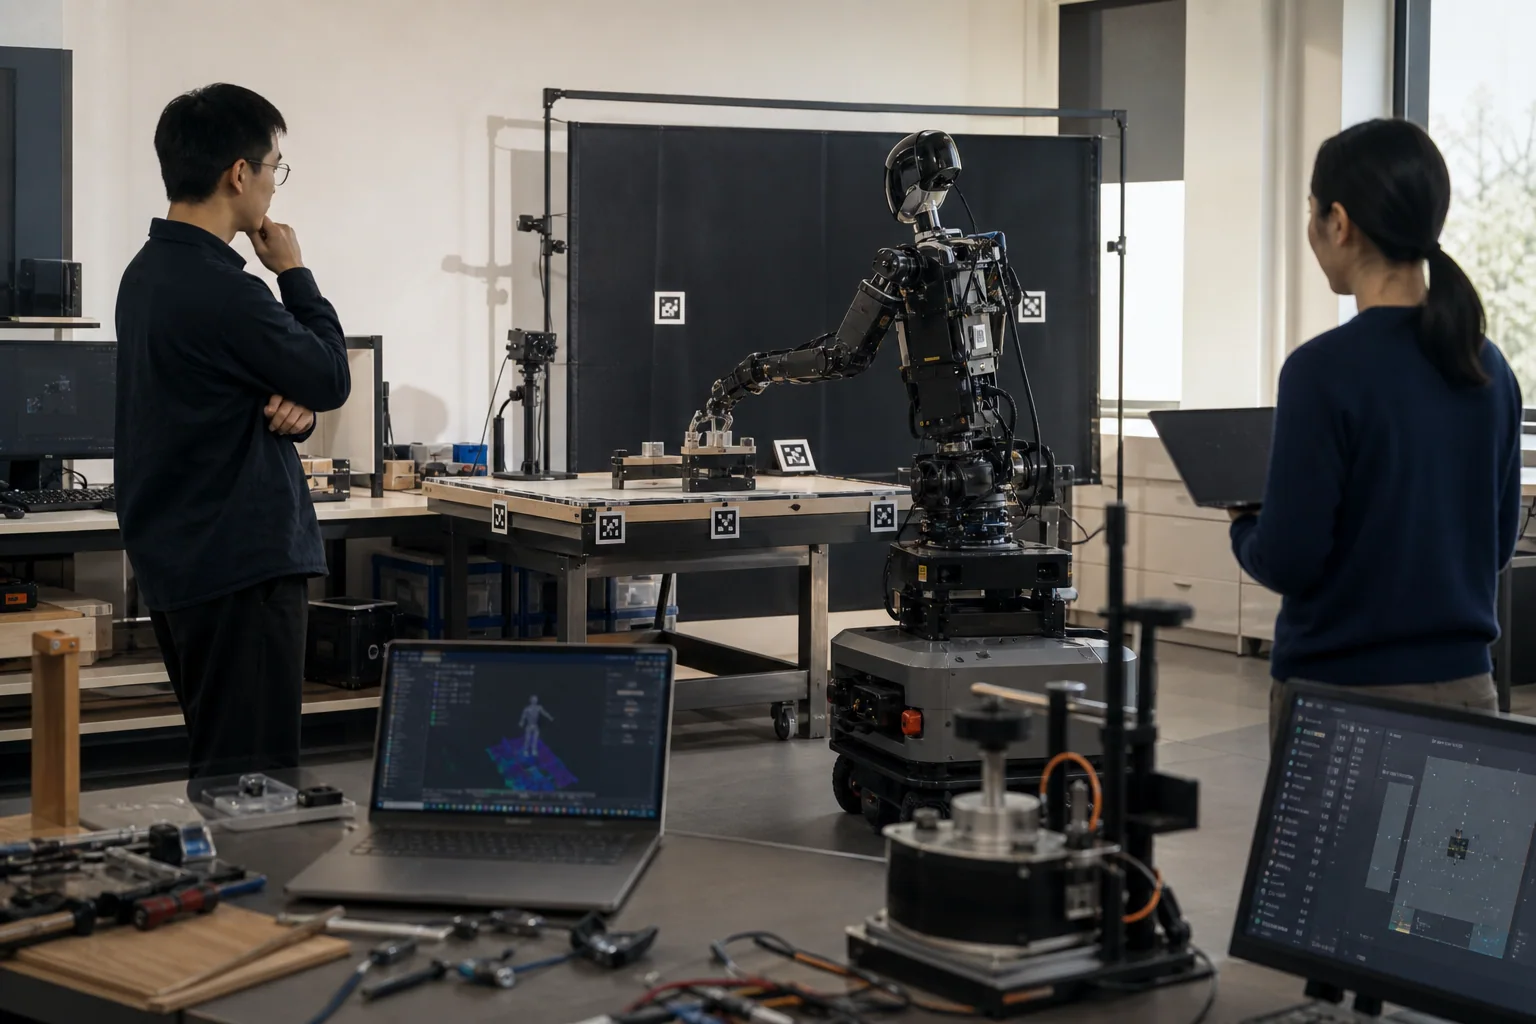
Compare two systems using their full attempt records
Participation is not confirmed until the public record is updated. Unconfirmed brands, names, venues and dates are not displayed.
Future directions may include mobility, perception, interaction and field operations. Numbers, titles, participants and dates will not be invented before scope and method are confirmed.